통합 검색
통합 검색
Mechanical Informatics
Refers to the information technologies to achieve efficiency, effectiveness, and reliability in the mechanical environment. The mechanical informatics researches in SSL have been conducted focusing on the automation and motion control systems. Major areas include:
Networked motor drive,
Motion controller software,
Model-based software development,
Industrial HMI (Human Machine Interface),
ROS (robot operating system), and
OPC UA (Unified Architecture) and gateway.
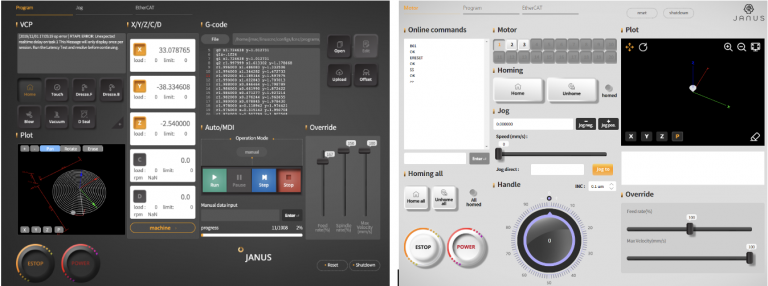
Janus - motion controller software
Janus is an integrated system software for precision motion programming and real-time control. It supports both RS-272 (g-code) and PMAC programming systems. Based on the EtherCAT and real-time kernel (RTAI or Xenomai) technologies, the software-based motion controller can perform feedback control over servo drives only with a few us of jitter at 10kHz frequency. For CNC applications, it includes g-code interpreter, real-time motion planning with look-ahead, and ladder-based PLC. And, for general motion applications, it has PMAC interpreter and online command shell. The enhanced HAL (Hardware Abstraction Layer) architecture guarantees hard real-time performance and facilitates adding new device and communication support.
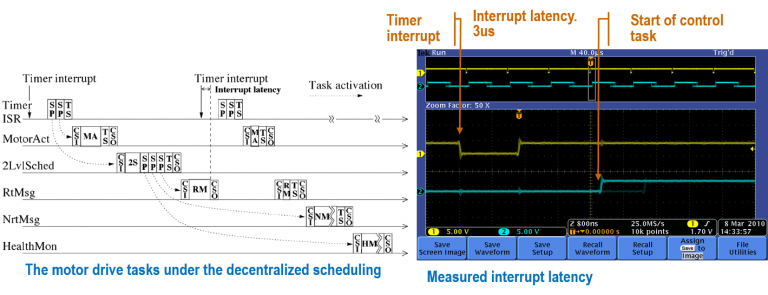
EtherCAT motor drive
For a precision motor drive, we have to cope with challenges in software design: "how to bound the end-to-end delay from message release to motor actuation" and "how to integrate all the control loops so that responsiveness is maximized". Our main contributions are (a) restructuring of drive software into a multi-task model, (b) period synthesis for minimized cycle time, and (c) stochastic analysis of end-to-end delay.
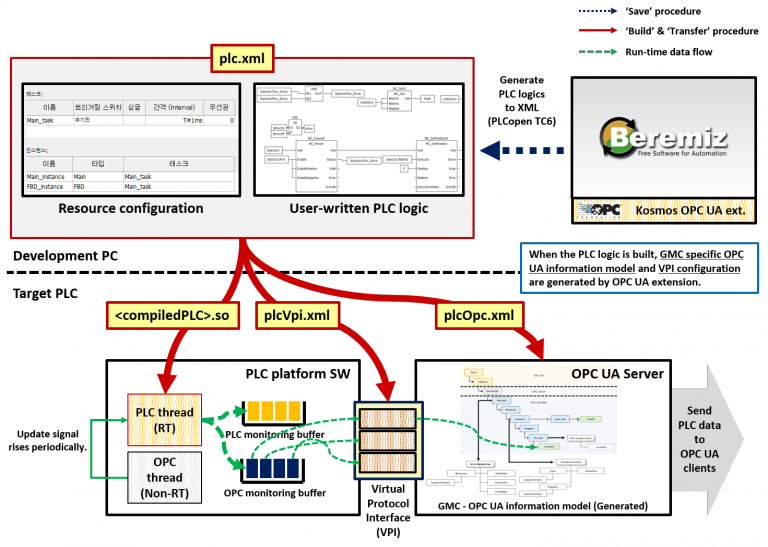
PLCopen OPC Unified Architecture
OPC Unified Architecture (UA) is a communication technology for secure, reliable and interoperable transport of information in control and automation environment. PLCopen OPC UA maps the IEC 61131-3 software model to the OPC UA information model. Based on the Beremiz PLC framework, the PLCopen OPC UA functions are implemented and evaluated.


